Neubility Unveils Billi, a Hybrid Humanoid That Adds Manipulation to Spatial Intelligence
TECHWORLD ·
✦ AI Summary
Neubility unveiled its hybrid humanoid Billi on the 29th.
Billi integrates mobility and manipulation based on spatial intelligence advanced through Neubi's field operations.
Neubility plans to verify Billi's task performance and operational stability in manufacturing, logistics, and other sites in the second half of this year.
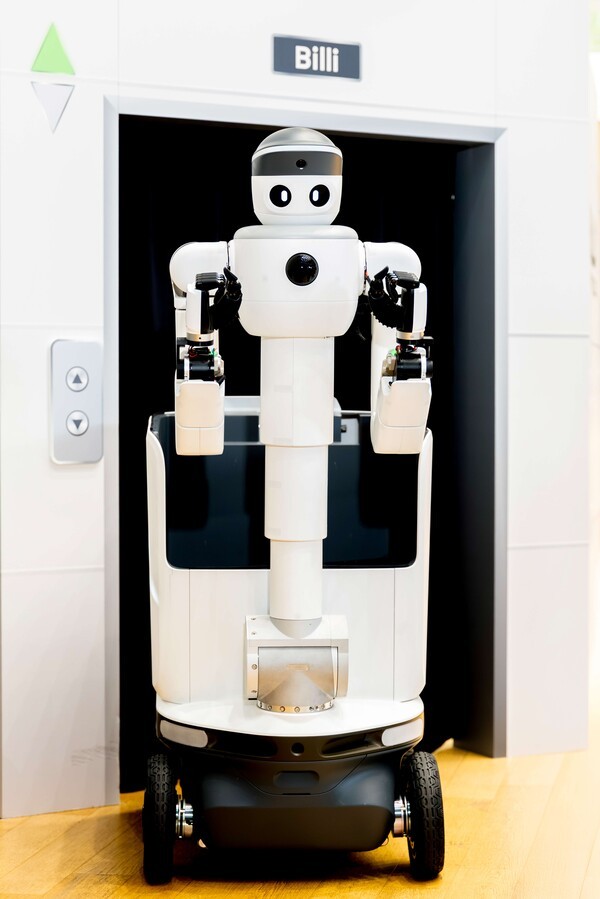
Neubility unveiled its hybrid humanoid robot, Billi, on the 29th. Billi is a robot built on domestic and overseas field operation experience and spatial intelligence. It is Neubility's first commercial form factor and a hybrid humanoid.
Based on its accumulated spatial intelligence, Billi integrates mobility and manipulation and connects movement and manipulation into a single workflow. As a result, it has expanded its capabilities from autonomous mobility to the execution of real physical tasks.
Neubility said Billi uses the advanced spatial intelligence it has developed through the field operation of its autonomous driving robot, Neubi. After recognizing work targets and the surrounding environment, Billi carries out material transport, loading, and equipment manipulation, and is designed to perform multiple tasks in a single flow.
Neubility plans to verify Billi's task performance and operational stability in manufacturing and logistics sites going forward. It also plans to expand the scope of spatial intelligence application to match the environments and tasks of each site.
Neubility said it plans to push ahead with field proof-of-concept (PoC) projects in the second half of this year. The purpose of this PoC is to verify Billi's task performance, operational stability, and on-site applicability in manufacturing and logistics environments. The initial PoC targets are partners in large-scale food and beverage manufacturing, partners in logistics and distribution, and partners in large-scale transportation complex facilities.
Neubility said it plans to secure operational and task data accumulated during the verification process. The data will be used to advance Billi's capabilities in spatial understanding, mobility and access, and task execution, including object recognition and manipulation. Neubility plans to create new data through field operations and reuse it to improve robot performance, building a field-based physical AI virtuous cycle. This virtuous cycle is a process that leads from field operations to data generation and then back to improved robot performance.
Neubility plans to advance Billi so it can respond flexibly to different environments and task conditions, and to expand Billi's applicability across industrial sites. To that end, Neubility has its own integrated platform, NCC (Neubility Control Center), and is providing an RX (robot transformation) solution based on it. The RX solution covers operations, monitoring, and maintenance, and is intended to support Billi's commercial services.
Kang Ki-hyuk, CEO of Neubility, said the company has stably operated robot services in a variety of real-world environments based on the operation of Neubi, and has continuously advanced robots' spatial understanding and autonomous driving performance based on field data. He explained that Billi is a hybrid humanoid developed based on domestic and overseas field operation experience and spatial intelligence.
Kang said Billi is a model that expands the scope of field work centered on autonomous mobility into areas that require object recognition and manipulation, taking the role of robots in real industrial settings one step further. He added that the company plans to provide an integrated RX solution that supports on-site adoption and stable operations with the goal of improving customer operational efficiency in a range of industries, including logistics and distribution, and that it plans to build a commercialization model for the continued real-world use of physical AI following Neubi.
Source: TECHWORLD · Lee Gwang-jae
Original: https://www.epnc.co.kr/news/articleView.html?idxno=407491
References
This article was produced with the help of an automated content generation algorithm.
Source: TECHWORLD
View originalThis article was summarized and organized by BizCrush based on the original article from TECHWORLD. For exact quotations and full details, please refer to the original article.