Robros Unveils IGRIS-C Full-Body Teleoperation, from Movement to Tasks
TECHWORLD ·
✦ AI Summary
Robros has released a video of the Real-Time Full Body Teleoperation technology for its bipedal humanoid IGRIS-C.
It has expanded the scope from upper-body-centered teleoperation to the lower body, enabling integrated control of walking, posture, balance, and upper- and lower-body movements.
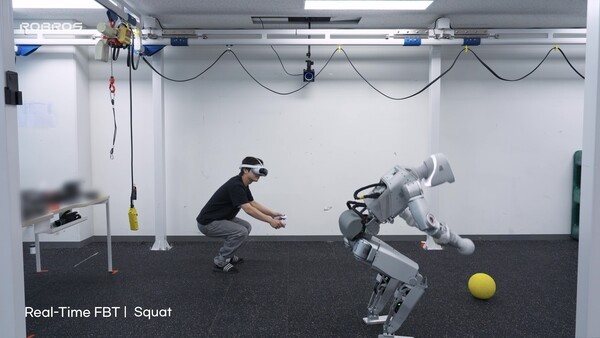
The released video shows simultaneous upper- and lower-body operation, sandbag striking, ball kicking, and interaction with surrounding environments and objects.
Robros has released a video of its self-developed bipedal humanoid IGRIS-C's Real-Time Full Body Teleoperation technology. Robros has previously and consistently unveiled teleoperation technology that enables real-time replication of upper-body human movements for IGRIS-C, and through this release, it has expanded the scope of application to the lower body as well.
As a result, Robros has advanced the technology to connect a worker's movements with the robot's full-body motions and to enable integrated control of walking, posture, balance, and upper- and lower-body movements. The released video includes examples of these expanded capabilities in action.
In the video, Robros said, viewers can see IGRIS-C's upper and lower body moving simultaneously in response to the worker's movements. It also said IGRIS-C can be seen striking a sandbag, kicking a ball with its foot, and interacting with its surrounding environment and objects.
Traditional upper-body-centered teleoperation has mainly been used for arm-based tasks in fixed locations. By contrast, the key to Real-Time Full Body Teleoperation is not replaying preassigned motions, but integrating the humanoid's movement and tasks in real time based on the worker's situational judgment.
Full-body teleoperation has a scope that responds to situations in which movement and tasks are combined, such as robot locomotion, posture changes, and dual-arm object manipulation. As a result, it can address more complex industrial settings than methods centered on arm work performed in a fixed position.
Robros said Real-Time Full Body Teleoperation makes it possible to link human situational judgment with the robot's movement and manipulation in real time. It also described the technology as an important one for applying humanoids to all industrial sites where advance definition is difficult.
Robros said the work data accumulated during the teleoperation process will be used in future humanoid training and technology advancement. It also said it plans to continue developing full-body teleoperation technology to support a wide range of tasks in line with industrial site needs.
Source: TECHWORLD · Lee Gwang-jae
Original: https://www.epnc.co.kr/news/articleView.html?idxno=407244
References
This article was produced with the help of an automated content generation algorithm.
Source: TECHWORLD
View originalThis article was summarized and organized by BizCrush based on the original article from TECHWORLD. For exact quotations and full details, please refer to the original article.